YOLOv4: High-Speed and Accurate Object Detection
Introduction
Object detection systems constantly need to balance accuracy, speed, and computational efficiency. Earlier YOLO versions made real-time detection possible, but there was still room for improvement in detection accuracy and training efficiency.
YOLOv4 was introduced in 2020 by Alexey Bochkovskiy, Chien-Yao Wang, and Hong-Yuan Mark Liao. The model was presented in the research paper “YOLOv4: Optimal Speed and Accuracy of Object Detection.”
YOLOv4 introduced improvements to the network architecture, training methods, and data augmentation techniques while maintaining strong real-time performance.
What is YOLOv4?
YOLOv4 is a single-stage object detection model designed to achieve a strong balance between speed and accuracy.
Its major components include:
- CSPDarknet53 backbone
- SPP (Spatial Pyramid Pooling)
- PANet-based feature aggregation
- Improved data augmentation
- Advanced training techniques
- CIoU-based bounding-box regression
These improvements helped YOLOv4 achieve better detection performance without requiring extremely expensive hardware.
YOLOv4 Architecture
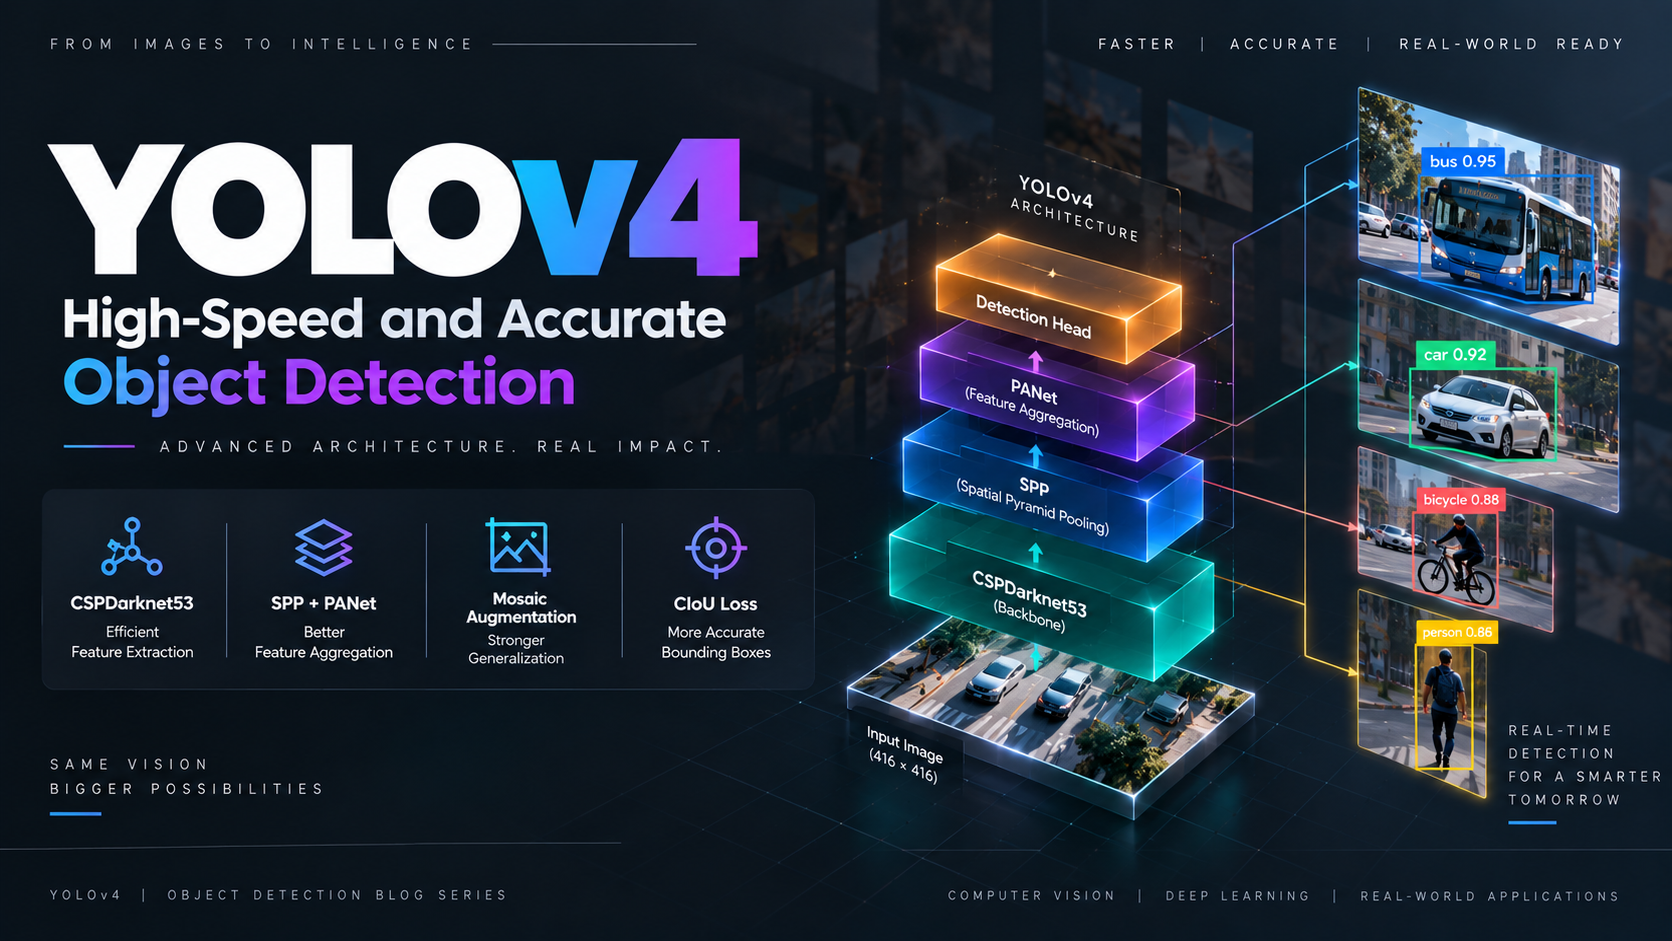
YOLOv4 can be broadly divided into three major parts:
1. Backbone — CSPDarknet53
The backbone extracts important visual features from the input image.
YOLOv4 uses CSPDarknet53, which combines Darknet53 with Cross Stage Partial (CSP) connections.
2. Neck — SPP and PANet
The Spatial Pyramid Pooling (SPP) module helps the network capture information at different spatial scales.
PANet (Path Aggregation Network) improves the flow of features between different levels of the network.
3. Detection Head
The detection head uses the extracted features to predict:
- Bounding boxes
- Objectness scores
- Class probabilities
Basic Workflow
Input Image → CSPDarknet53 → SPP + PANet → Detection Head → Bounding Boxes + Classes
Major Improvements in YOLOv4
1. CSPDarknet53
CSPDarknet53 improves feature extraction while reducing unnecessary computation and improving information flow through the network.
2. Spatial Pyramid Pooling
SPP allows the model to collect information using different receptive-field sizes. This improves the network's ability to understand objects at different scales.
3. PANet
PANet improves feature aggregation by allowing information from different network levels to be combined more effectively.
4. Data Augmentation
YOLOv4 uses advanced augmentation methods such as Mosaic augmentation, which combines multiple training images into a single image.
This helps the model learn from objects appearing at different sizes and positions.
5. CIoU Loss
YOLOv4 uses Complete IoU (CIoU) for bounding-box regression, helping improve the accuracy of predicted bounding boxes.
Key Features of YOLOv4
- Real-time object detection
- CSPDarknet53 backbone
- SPP feature extraction
- PANet feature aggregation
- Mosaic data augmentation
- Improved bounding-box regression
- Strong speed and accuracy balance
- Suitable for practical computer vision applications
Advantages of YOLOv4
YOLOv4 provides:
- High detection accuracy
- Fast inference
- Efficient feature extraction
- Better detection across different object sizes
- Improved training techniques
- Good performance on standard hardware
Its focus on practical performance made it useful for real-world computer vision applications.
Limitations of YOLOv4
Despite its improvements, YOLOv4 still has some limitations:
- Large models require considerable computational resources.
- Small and heavily occluded objects can remain challenging.
- Training custom models can require significant time and GPU resources.
- There is still a trade-off between model size, speed, and accuracy.
YOLOv3 vs YOLOv4
| Feature | YOLOv3 | YOLOv4 |
|---|---|---|
| Backbone | Darknet-53 | CSPDarknet53 |
| Feature Processing | Multi-scale | SPP + PANet |
| Data Augmentation | Standard techniques | Advanced techniques |
| Bounding Box Loss | IoU-based approaches | CIoU |
| Accuracy | High | Improved |
| Speed | Real-time | Real-time |
Applications of YOLOv4
YOLOv4 can be used for:
- Vehicle detection
- Pedestrian detection
- Traffic monitoring
- Surveillance systems
- Industrial inspection
- Retail analytics
- Robotics
- Real-time video analysis
- Autonomous systems
Conclusion
YOLOv4 significantly improved the balance between object detection speed and accuracy. Its CSPDarknet53 backbone, SPP, PANet, Mosaic augmentation, and improved bounding-box regression contributed to stronger detection performance.
YOLOv4 demonstrated that advanced neural-network architectures and training techniques could be combined to create a highly capable real-time object detector.
Comments (0)
No comments yet. Be the first to share your thoughts!
Join the Conversation
Please log in to your Teltam account to post a comment on this article.
Log In to Comment